PLATFORM / ENGINEERING
ROV V1
A supervised shallow-water platform for stereo vision research.
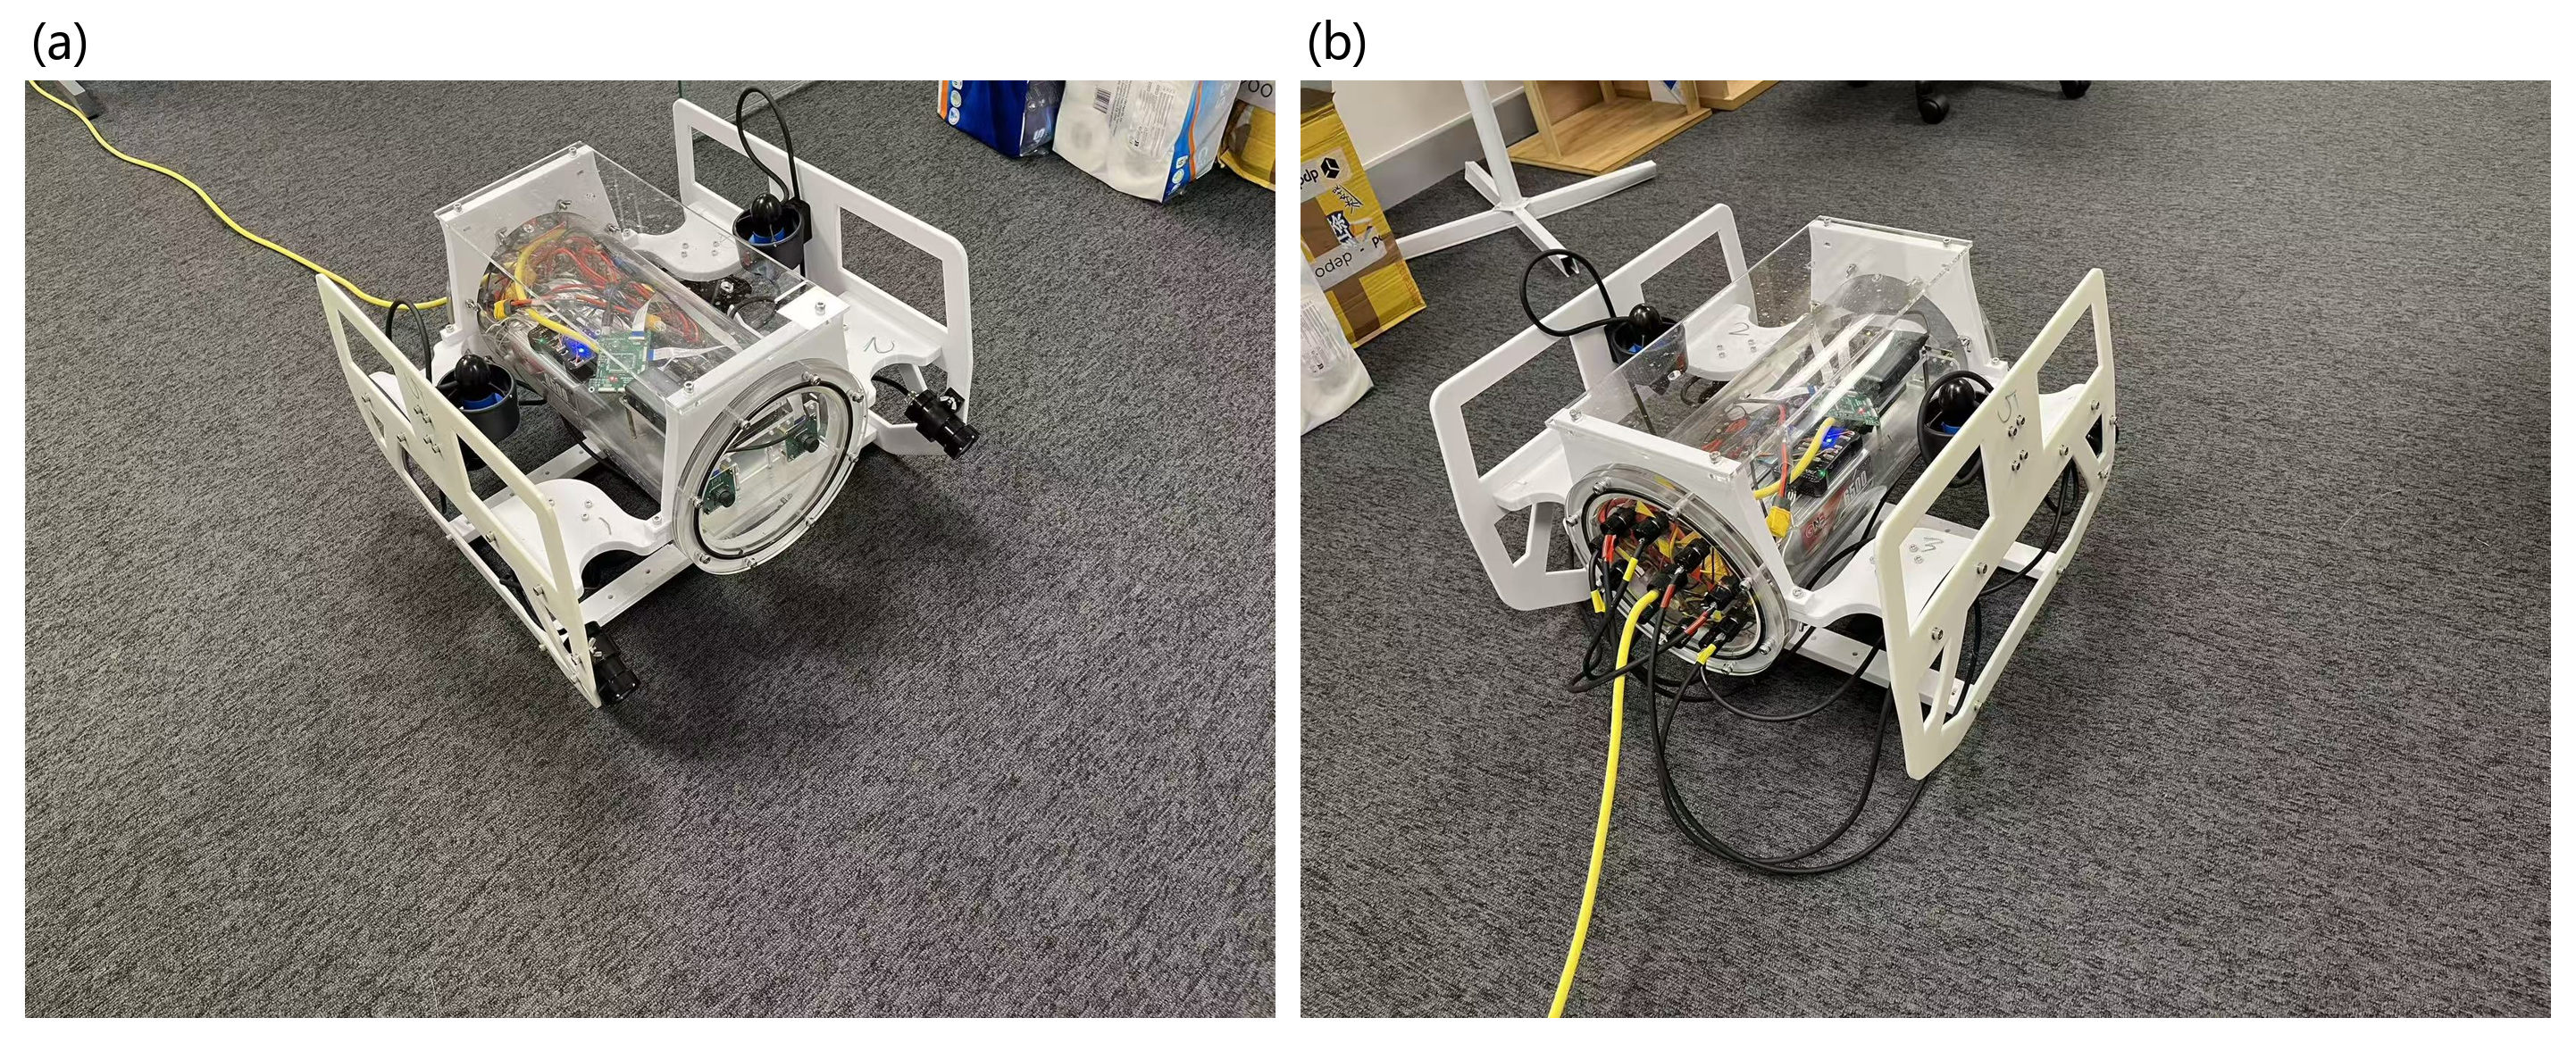
From hardware to experiment
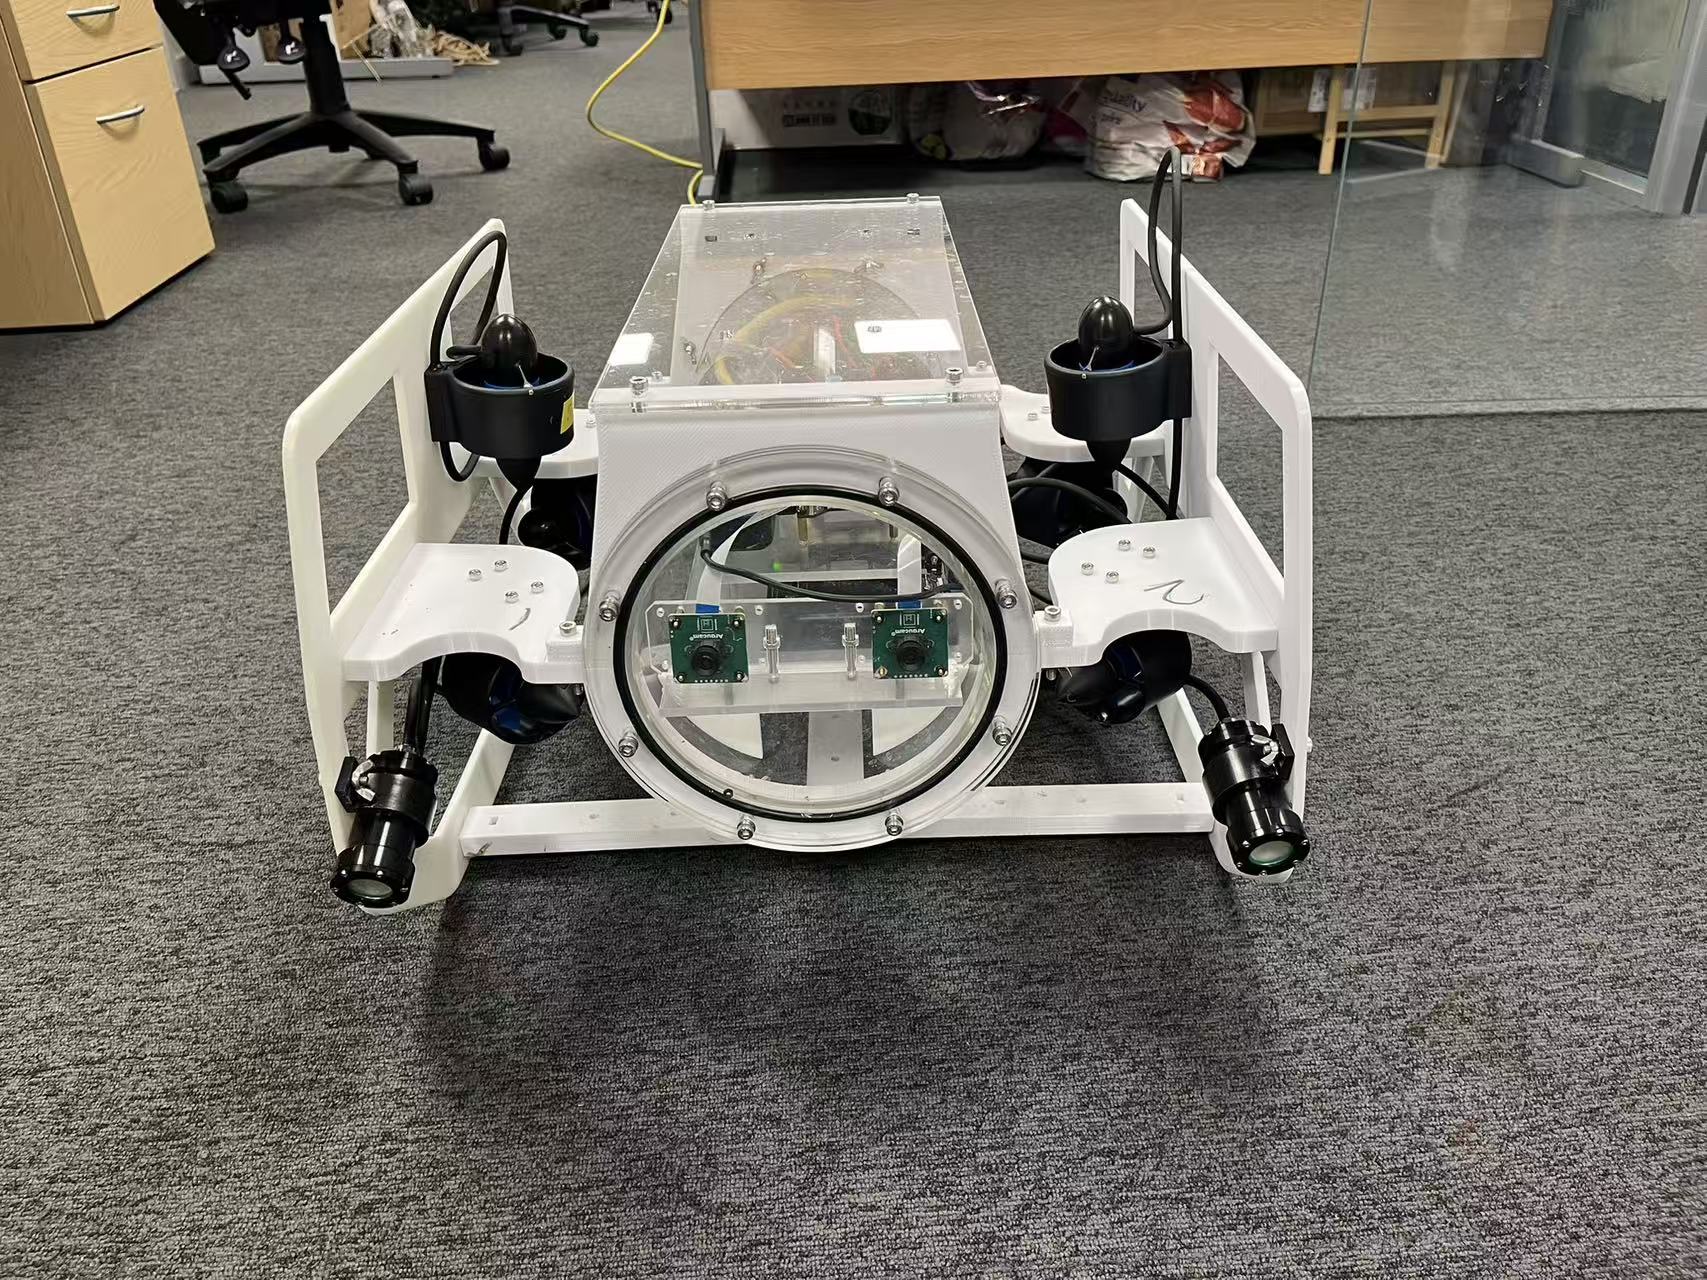
The platform brings together a commercial acrylic enclosure, propulsion and lighting, an internal electronics rack and a custom stereo camera mount. It supported the underwater data collection used in York-Tank.
My contribution
Mechanical design and integration, stereo sensor mounting, electronics and control-interface integration, and supervised shallow-water testing. The engineering work connects camera geometry and payload packaging with the practical needs of data acquisition.
Engineering resources
The public engineering repository provides the released hardware designs, functional wiring diagrams, assembly documentation and author software. File licences and dependencies are documented in the repository.
Browse released engineering filesOperating scope
The platform is intended for supervised shallow-water research. Existing use supports platform integration and data acquisition; no maximum-depth, endurance or autonomous-navigation performance is claimed here.
GET IN TOUCH
Research, engineering and collaboration.
For research collaboration and robotics R&D enquiries, please contact me by email.