DATASET / 2026
York-Tank
A degradation-aware and difficulty-stratified stereo dataset for underwater visual SLAM.
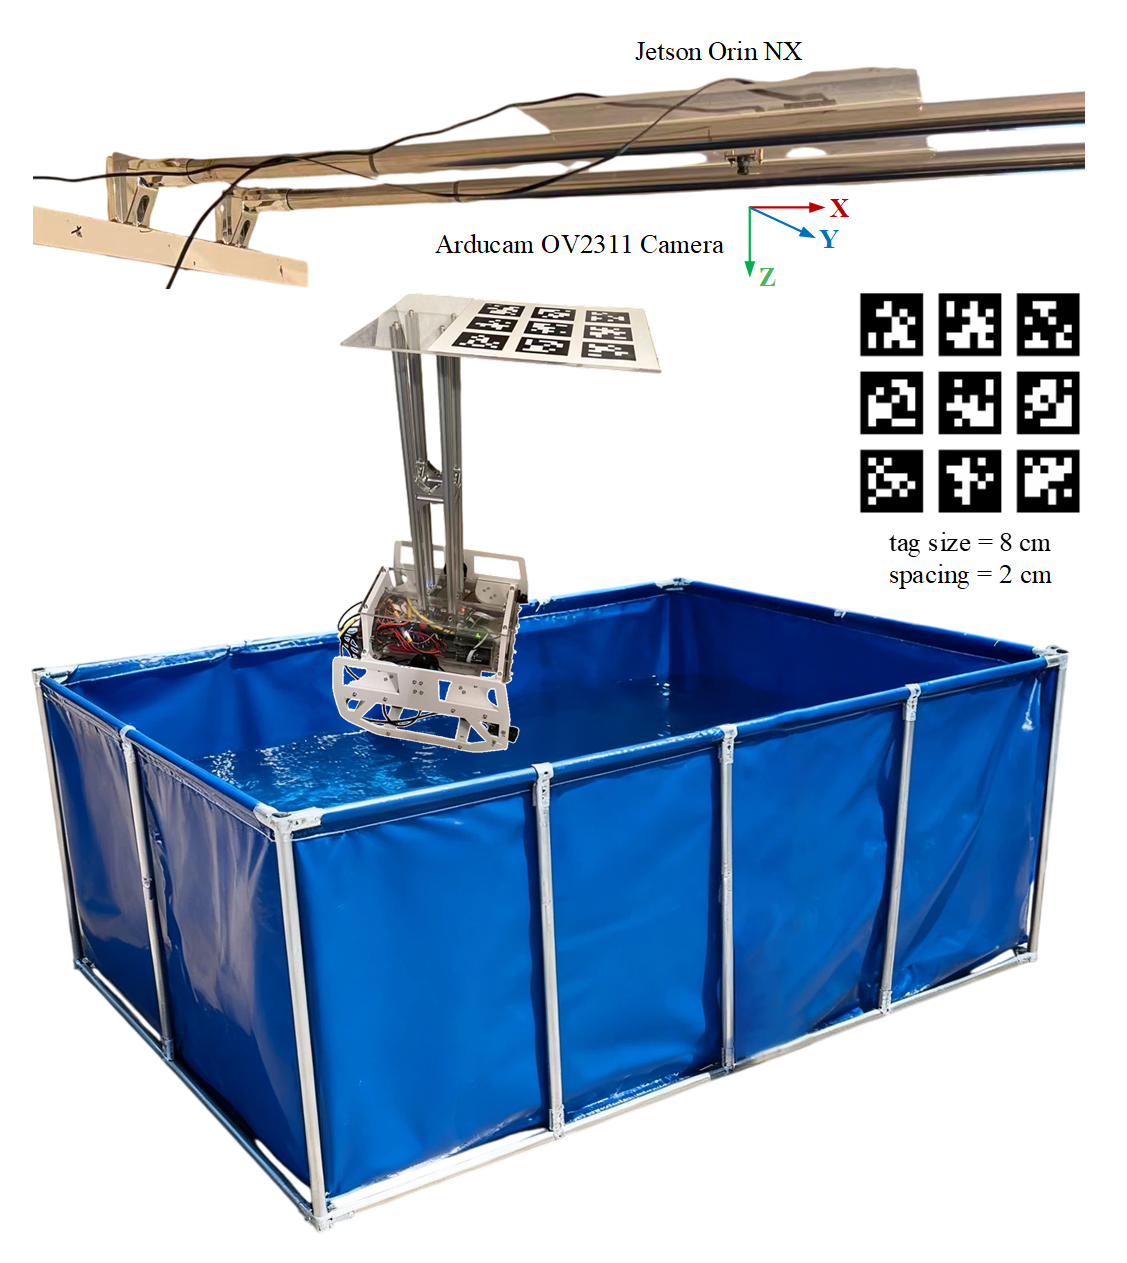
Research question
How do different types and levels of visual degradation affect SLAM tracking, localization and failure? York-Tank provides sequences recorded in a shared tank scene to support structured comparisons.
- Sequences
- 16
- Stereo pairs
- 18,948
- Degradation factors
- 5
- Difficulty levels
- 4
My contribution
My work spans the underwater platform, stereo calibration and rectification, data acquisition and processing, and the organization of SLAM experiments. The associated paper was co-authored with Mark Post.
Data & sequence structure
The published benchmark contains rectified grayscale stereo images at 1280 × 800 pixels and 20 Hz. The release also includes IMU measurements, calibration materials, raw AprilTag-array reference poses and ROS bags.
| Sequence | Condition | Level | Stereo pairs |
|---|---|---|---|
1_reference1 | Baseline | 1 | 1,339 |
2_reference2 | Baseline | 1 | 1,235 |
3_dark_easy | Low illumination | 2 | 1,234 |
4_dark_hard | Low illumination | 3 | 1,452 |
5_uneven_easy | Non-uniform illumination | 2 | 1,237 |
6_uneven_hard | Non-uniform illumination | 3 | 1,179 |
7_fastmotion_easy | Fast motion | 2 | 1,157 |
8_fastmotion_hard | Fast motion | 3 | 1,330 |
9_fewtexture_easy | Texture deficiency | 2 | 1,184 |
10_fewtexture_hard | Texture deficiency | 3 | 1,310 |
11_dynamic_easy | Dynamic interference | 2 | 1,151 |
12_dynamic_hard | Dynamic interference | 3 | 1,205 |
13_hybrid | Hybrid degradation | 4 | 902 |
14_hybrid | Hybrid degradation | 4 | 1,198 |
15_hybrid | Hybrid degradation | 4 | 931 |
16_hybrid | Hybrid degradation | 4 | 904 |
| Total | 18,948 | ||
Download & use
Zenodo v2 is the complete published release, distributed as 16 sequence archives and one support archive, approximately 51.1 GB in total. Extract the archives into the same destination. The GitHub README documents the release layout and access instructions.
The v1 record is an earlier single-sequence preview. IMU data are included as measurements; this does not imply that the published stereo evaluation used visual-inertial fusion.
Citation
Chengdong Zhu and Mark Post. York-Tank: A Degradation-Aware and Difficulty-Stratified Stereo Dataset for Underwater Visual SLAM. Sensors 2026, 26(20), 6567. https://doi.org/10.3390/s26206567
GET IN TOUCH
Research, engineering and collaboration.
For research collaboration and robotics R&D enquiries, please contact me by email.