ROBOT CONTROL / AGRICULTURAL ROBOTICS
ATArm · 3D position control
Local Jacobian control, external pose feedback and offline verification for a flexible robotic arm.
The platform behind the control software
Existing field photographs show the flexible arm, camera payload and actuator area. My work presented here concerns the control software and interfaces.
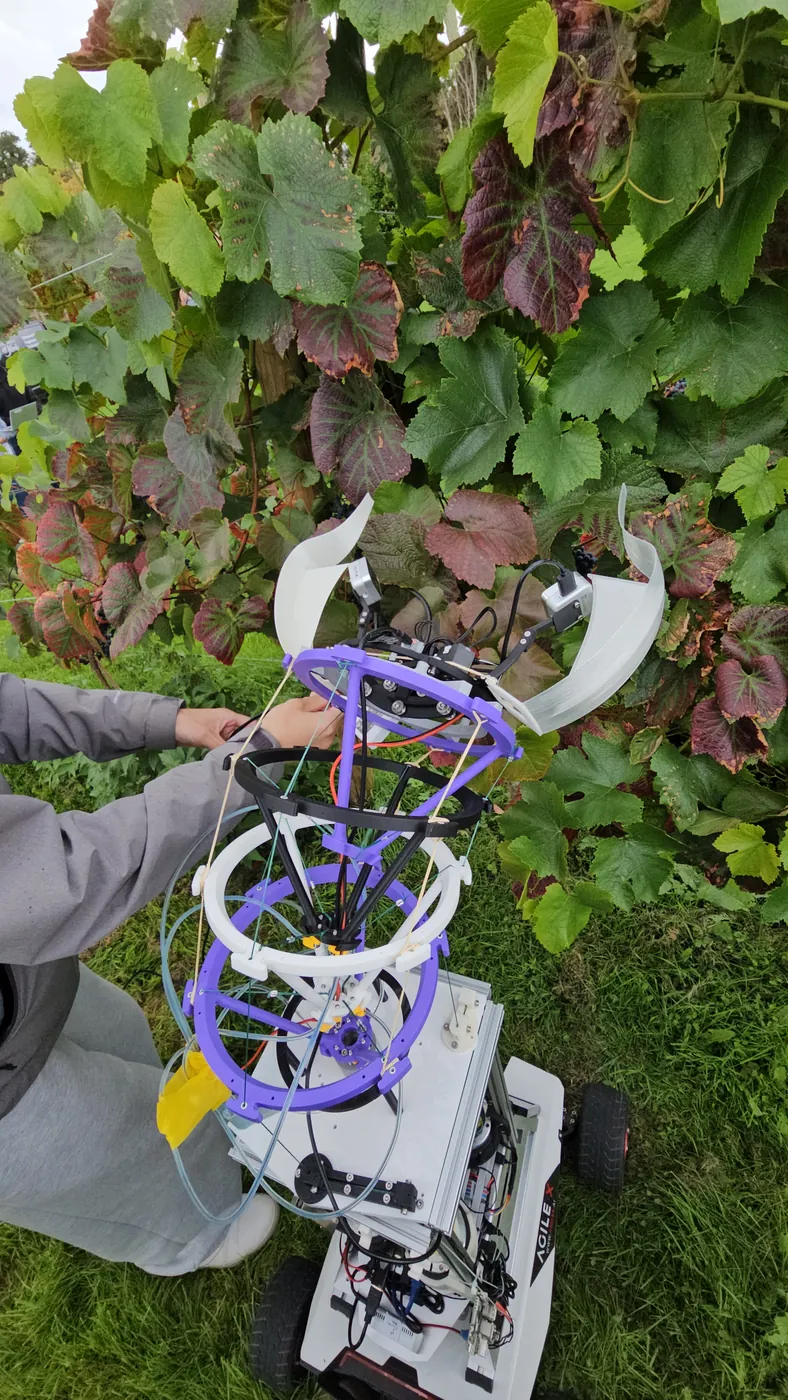
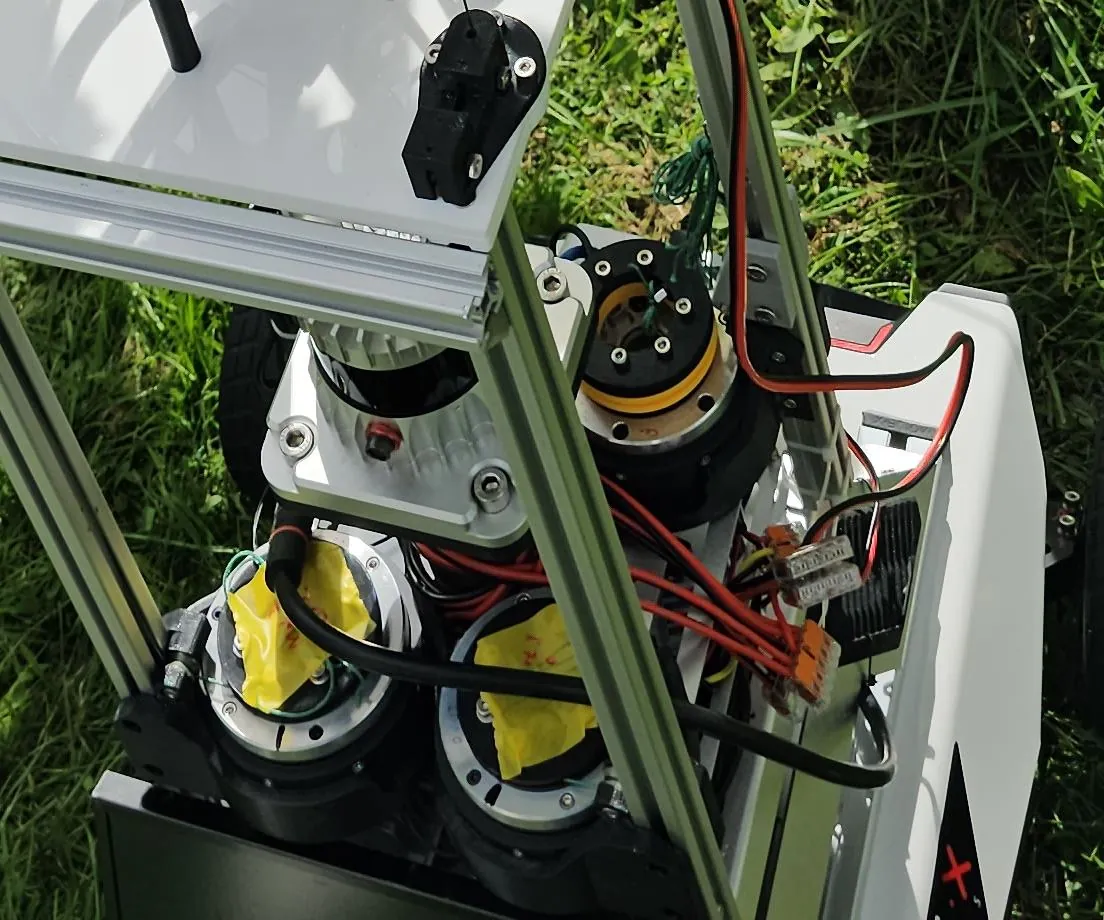
These photographs document the existing platform. The current 3D controller is validated offline and awaits physical commissioning.
The control task
The agricultural robotics project needs a flexible arm to reach a target position using external pose feedback. I work on the control software and its interfaces, extending an existing ATArm framework that already includes motor-position feedback.
My implementation work
My work
- Developed local numerical-Jacobian control and alternating/coordinated extension–bending strategies.
- Connected ROS pose feedback, coordinate transforms and measurement freshness checks.
- Added actuator allocation, bounded updates and independent final-position checks; tested with simulation and fake serial interfaces.
The controller estimates a local numerical Jacobian between virtual extension/bending inputs and xyz motion. Damped inversion produces small bounded corrections, which are allocated to four actuator channels.
The ROS bridge accepts externally estimated metric poses. Coordinate conversion, stale-data rejection and stable measurement windows sit between sensing and control. The controller waits for updated measurements after motion and checks the final xyz target independently.
Outputs and verification
The outputs include control modules, pose-interface code, configuration checks, offline tests and commissioning documentation. Simulation, ROS scenarios and fake serial interfaces exercise convergence and failure handling.
The current version has not been commissioned on the physical arm. Calibration and positioning accuracy remain to be measured on hardware. This project currently covers 3D position control; its pose bridge consumes estimated poses rather than processing raw images.
Project code and context
This work extends an existing control codebase and retains upstream-source records. The repository has no unified open-source licence; source provenance and permissions are described in its documentation.
GET IN TOUCH
Research, engineering and collaboration.
For research collaboration and robotics R&D enquiries, please contact me by email.